Sonar-Based Multi-Sensor Fusion Algorithms for Autonomous Underwater Robot Navigation
DOI:
https://doi.org/10.64972/dea.2024.v3i1.4353d:30-42Keywords:
Autonomous Underwater Robot, Sonar Navigation, Multi-sensor Fusion, Robust FilteringAbstract
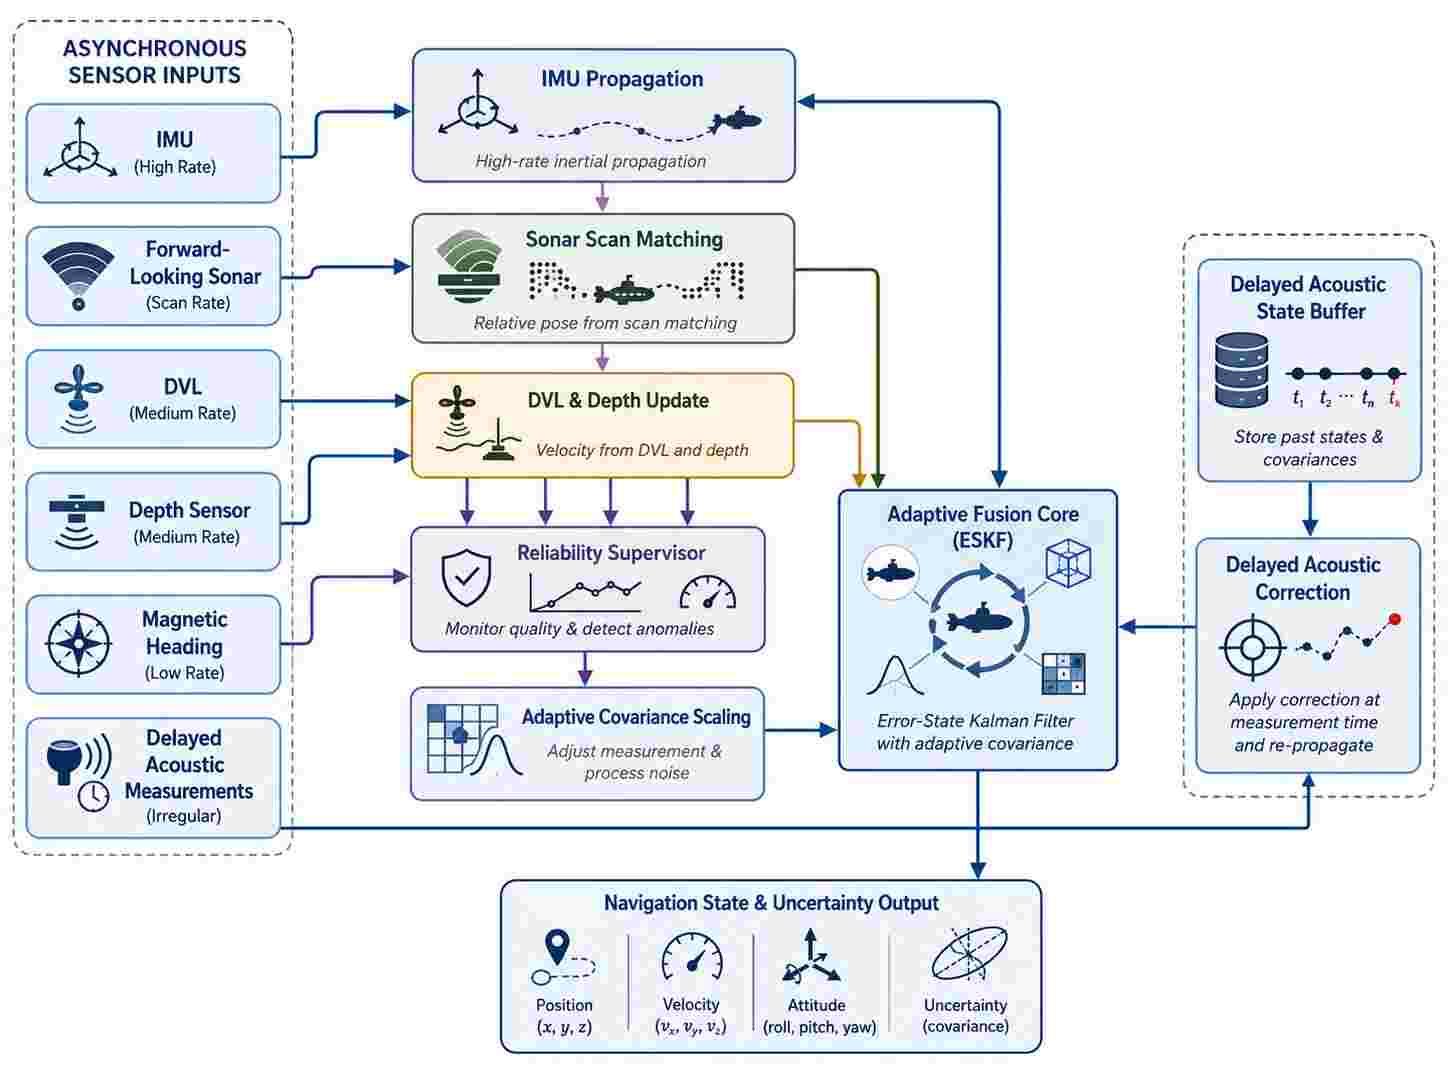
A stable positioning system is required for autonomous underwater vehicles (AUVs) in confined waters such as reservoirs, harbors, subsea inspection sites and long-range surveys without satellite navigation. Sonar is one of the few sensing modes capable of observing underwater geometry at practical distances, but sonar data are subject to multipath, acoustic shadowing, beam spreading, sparse features, and non-Gaussian outliers. A Robust Sonar-Based Multi-Sensor Fusion Algorithm for Autonomous Underwater Vehicle Navigation is Proposed in this Paper. The above methods integrate forward-looking sonar scan matching, inertial propagation, Doppler velocity log measurements, pressure-depth observations and delayed acoustic positioning to form a single adaptive estimation system. Build a motion-state model for position, velocity, attitude and sensor biases. Sonar residuals are evaluated via innovation gating and robust weighting, and DVL dropout and acoustic latency are addressed by covariance inflation and delayed-state correction. Example experiments on a simulated and tank-based AUV trajectory show that the proposed method reduces the mean horizontal position error from 2.84m for inertial-DVL fusion and 1.72m for conventional sonar EKF fusion to 0.94m. The final drift is also reduced to 0.37% of the travelled distance, stable depth estimation is maintained at below 0.18 m root mean square error, and real-time performance of 28.6 ms per fusion cycle is preserved. Therefore, stable Sonar-centric fusion can improve the accuracy and stability of underwater navigation and operations without the need for external GPS or dense artificial landmarks.
Downloads
Published
How to Cite
Issue
Section
License
Copyright (c) 2024 Faisal Al-Habsi

This work is licensed under a Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License.