Improved CoTNet-SE Model for Smart Helmet Positioning Error Correction Under UWB and Inertial Sensor Sequences
DOI:
https://doi.org/10.64972/dea.2026.v5i3.4323d:28-40Keywords:
UWB-IMU Fusion, Smart Helmet Localization, Positioning Error Correction, CoTNet-SE, Construction SafetyAbstract
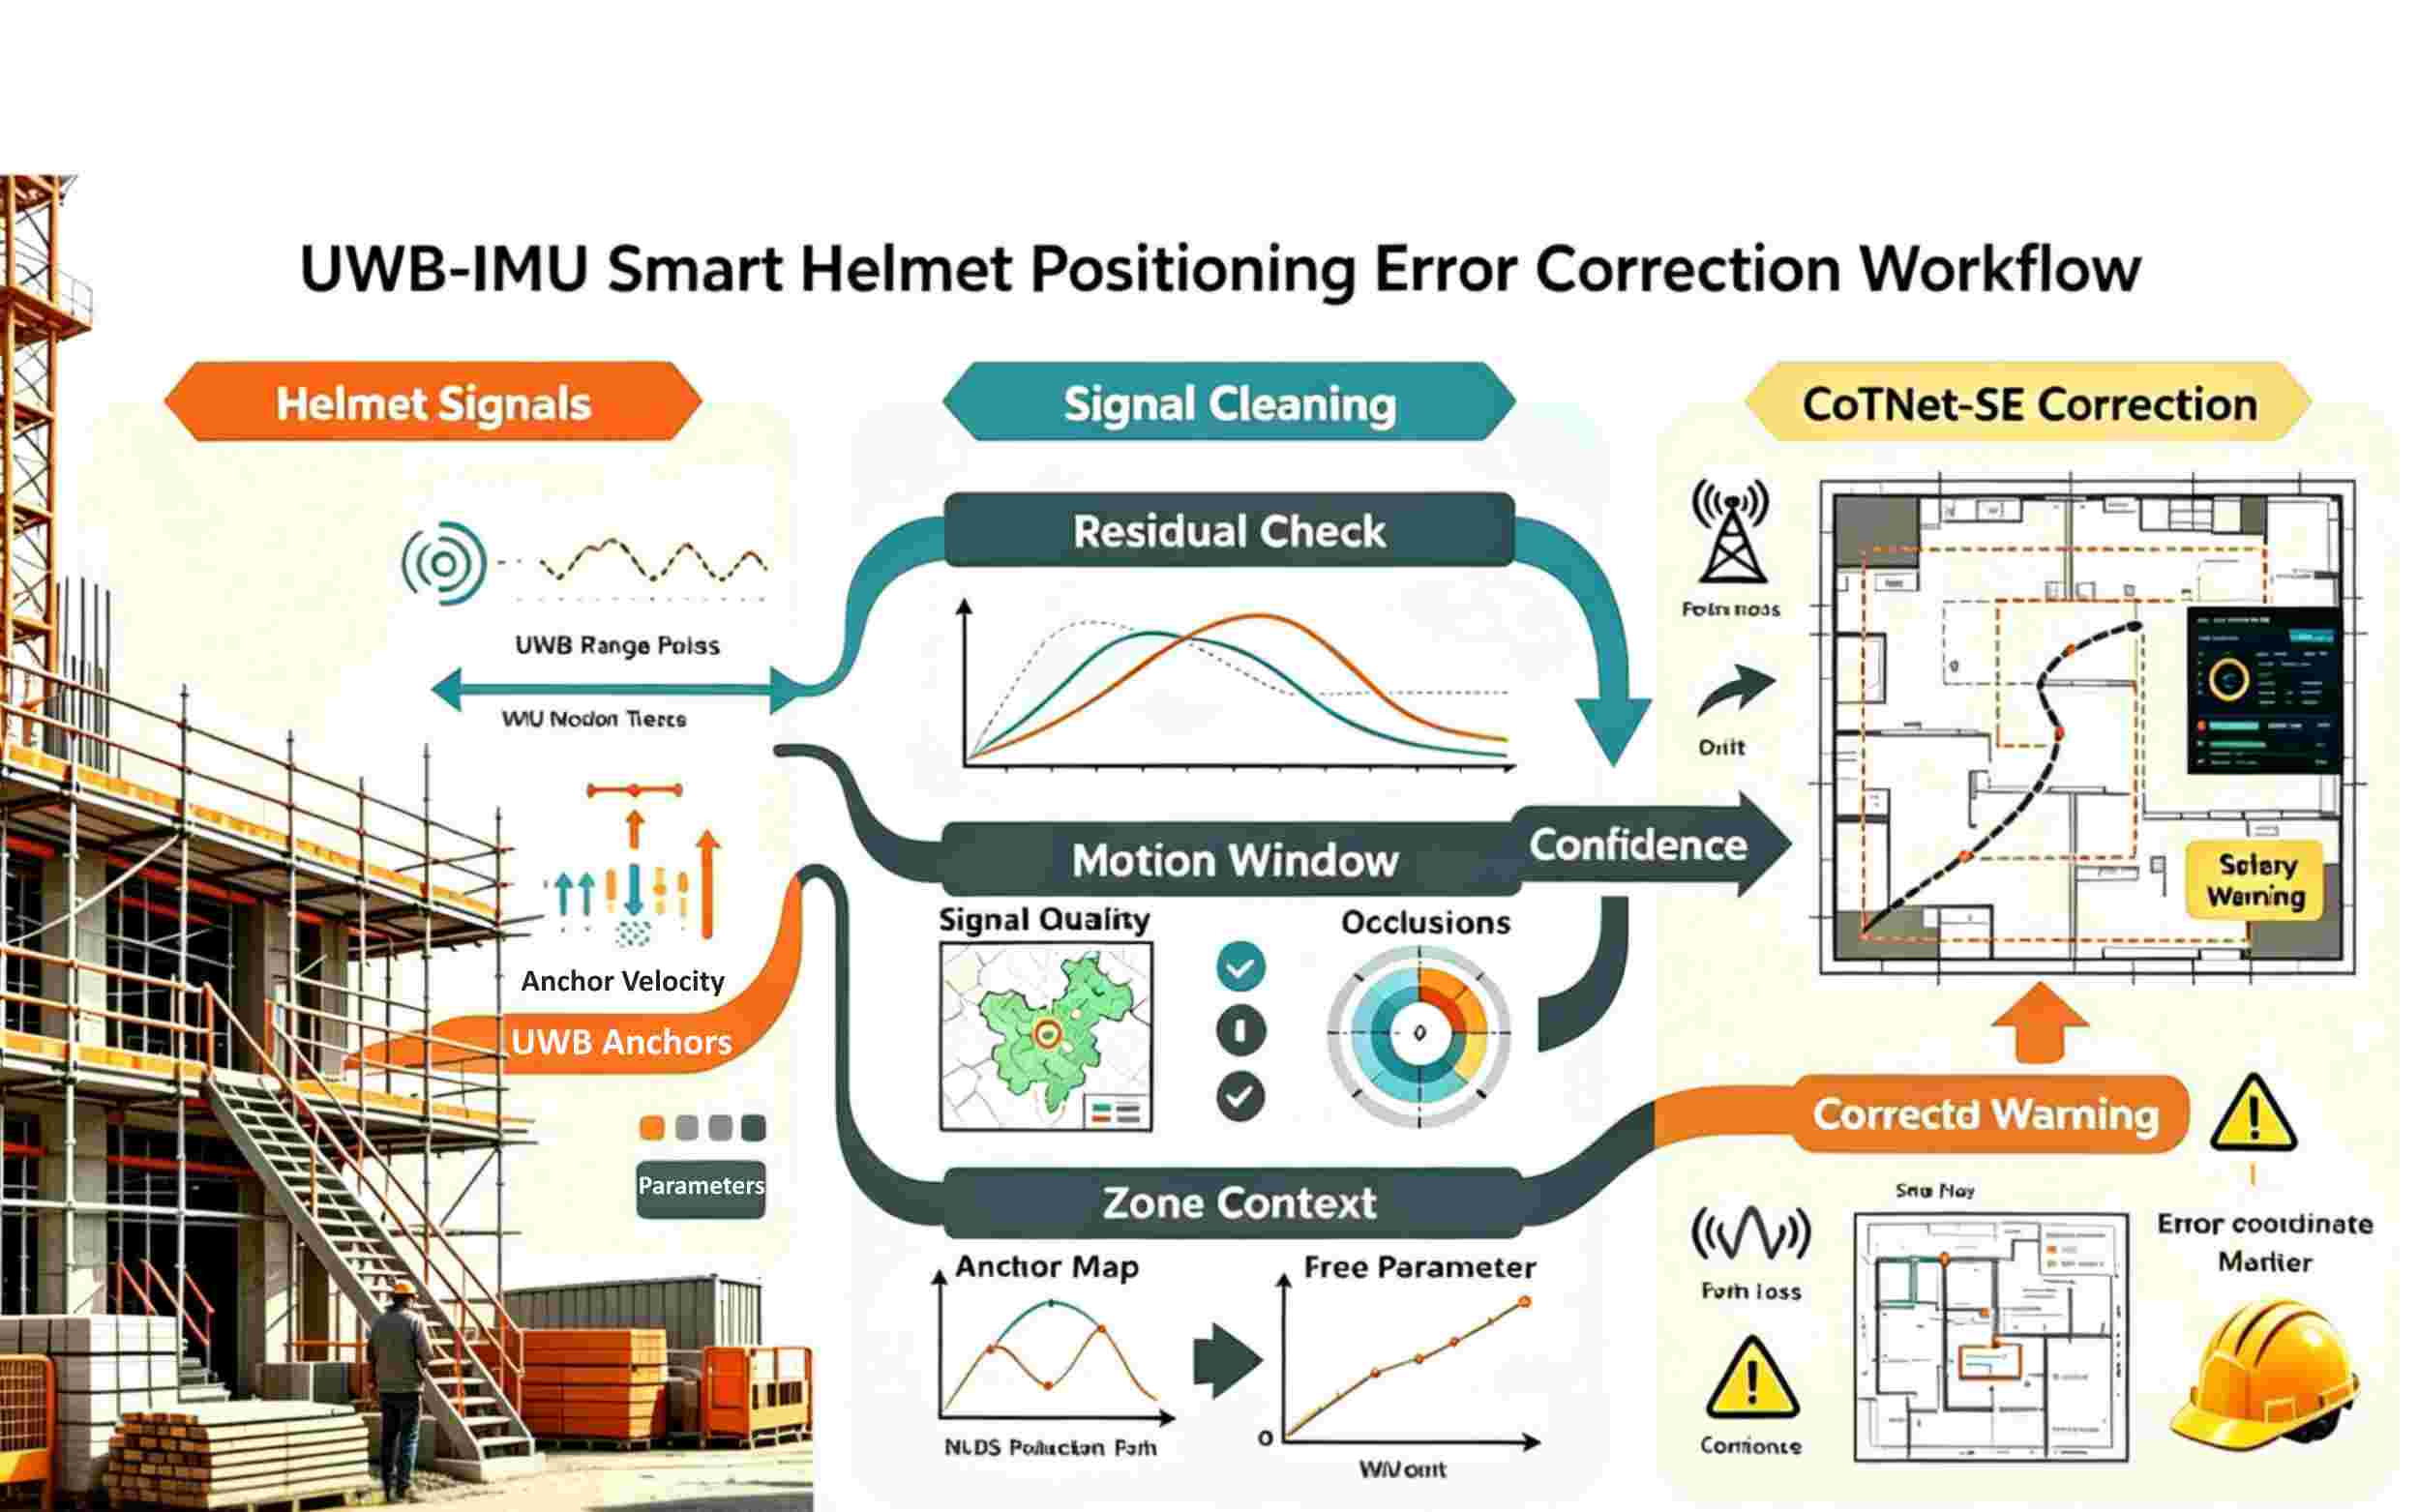
This study develops an improved CoTNet-SE model for smart helmet positioning error correction under UWB and inertial sensor sequences. The task addresses construction-site localization errors caused by temporary barriers, steel structures, material stacks, moving equipment, worker posture changes, non-line-of-sight ranging, inertial drift, and brief trajectory interruptions. A simulated dataset is constructed with 42 work zones, 18 UWB anchors, 96 helmet terminals, and 1.48 million synchronized UWB-IMU samples collected from open spaces, scaffold corridors, stair entrances, underground passages, and material storage yards. The model builds UWB range residuals, IMU motion windows, anchor-visibility masks, signal-confidence descriptors, zone-distance features, and trajectory context features. Contextual Transformer Convolution learns local-to-global error patterns, while Squeeze-and-Excitation recalibration selects reliable sensing channels before coordinate correction and safety-zone scoring. Compared with raw UWB, Kalman filtering, LSTM fusion, temporal convolution, and attention-only baselines, the model reduces mean positioning error from 0.74 m to 0.39 m, decreases 95th-percentile error from 1.82 m to 0.91 m, and lowers safety-zone false alarms by 31.6%. The average inference latency is 8.7 ms per helmet window on a desktop setting, supporting edge-side updates. The method remains limited by simulated data and requires real-site validation, anchor calibration, privacy protection, weather testing, and map-update integration.
Downloads
Published
How to Cite
Issue
Section
License
Copyright (c) 2026 Damian Kaczmarek, Hubert Kasprzyk, Alicja Gruszka

This work is licensed under a Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License.